Projects
Robotics, embedded systems, hardware, audio, and machine learning.
Terra Labs: Cove
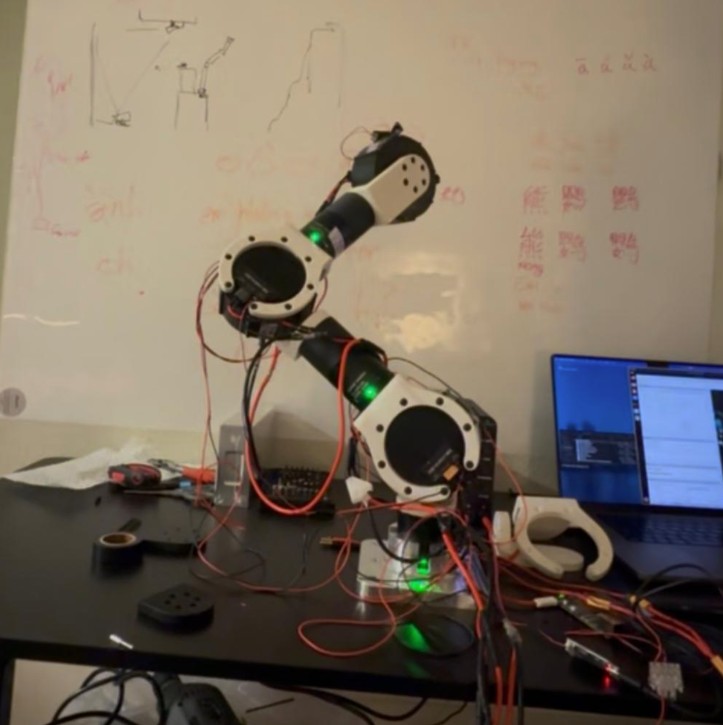
As Electronics Co-Lead, I help integrate a seven-degree-of-freedom autonomous robotic arm built around a Teensy 4.1, Raspberry Pi 5, and CAN bus actuator network. My work spans embedded communication, hardware bring-up, actuator interfaces, power distribution, and the safety boundary between low-level firmware and ROS 2 control.
- Teensy 4.1
- Raspberry Pi
- CAN bus
- ROS 2
Custom high-fidelity speaker
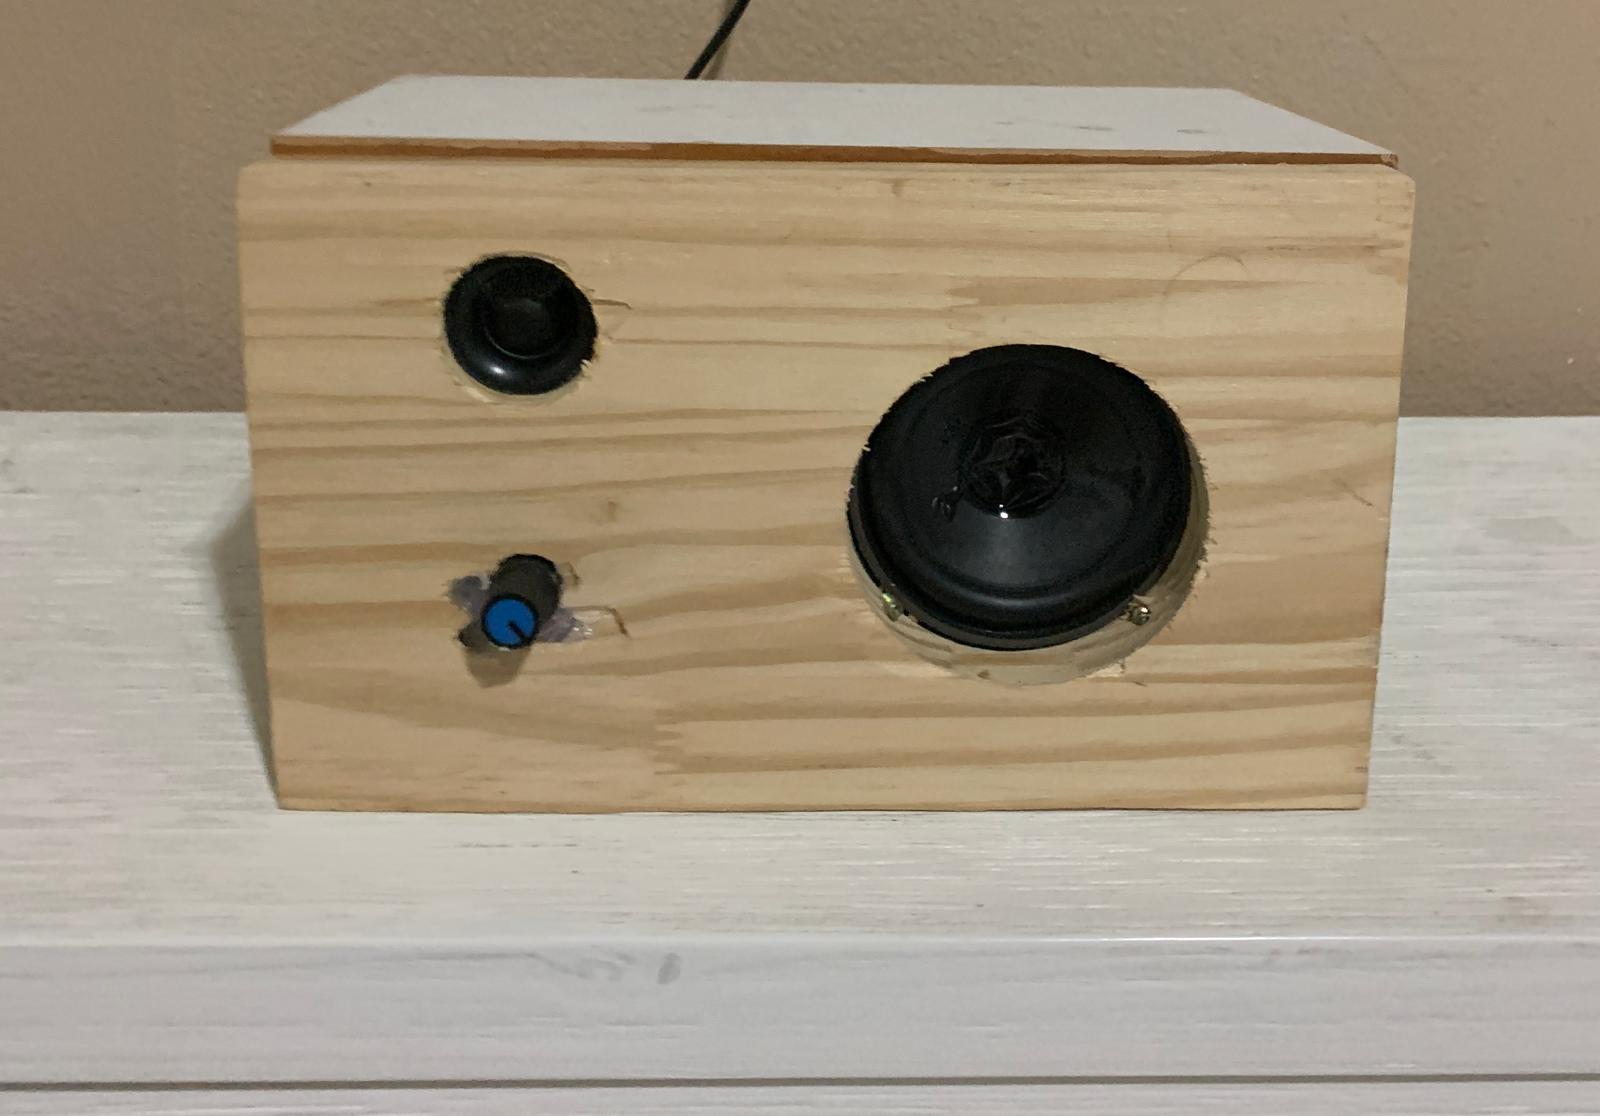
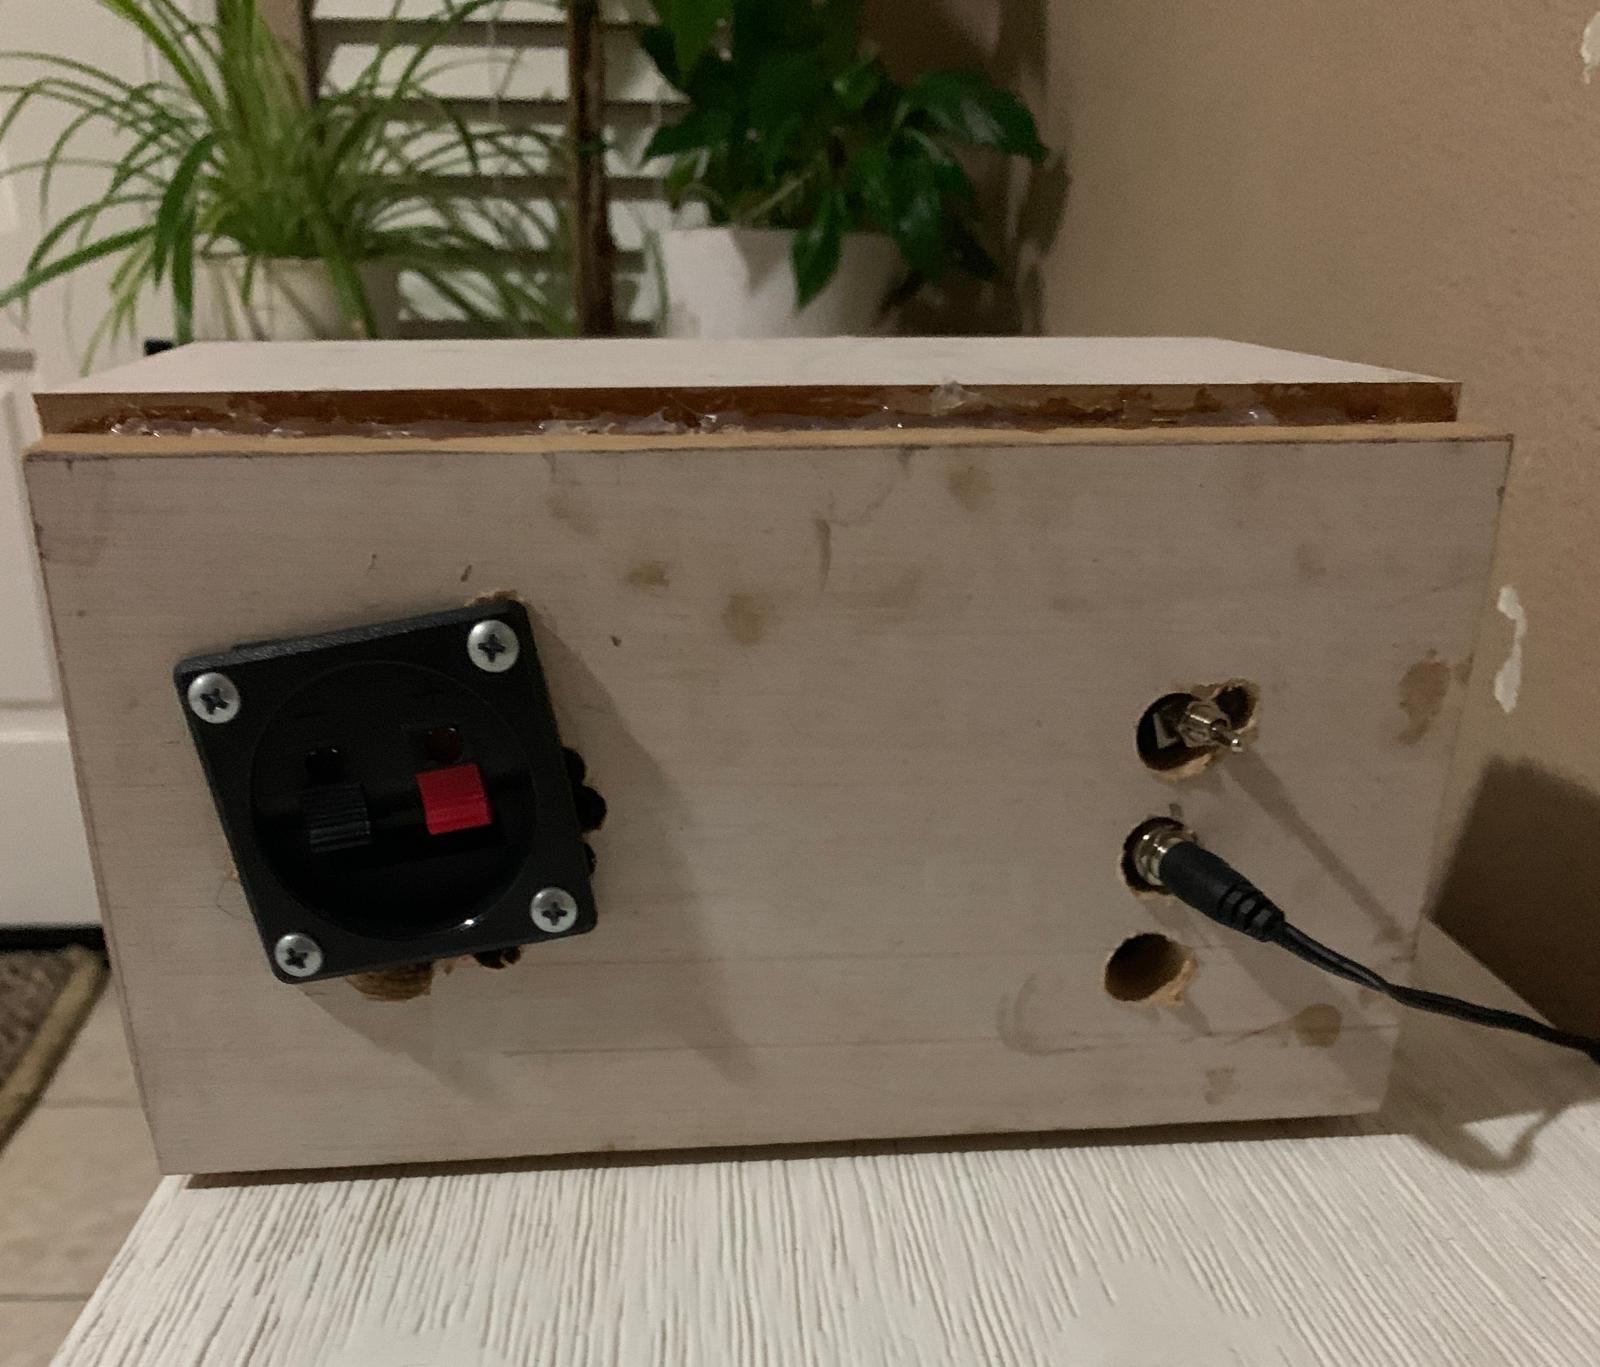
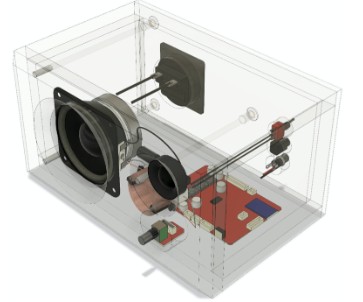
I designed and built a Bluetooth speaker from first principles: enclosure modeling, driver selection, analog crossover design, soldering, wiring, and assembly. Acoustic testing with signal generators and oscilloscopes closed the loop between the calculations and what the finished system actually produced.
- Analog circuits
- Acoustics
- Fabrication
Unconditional audio generation
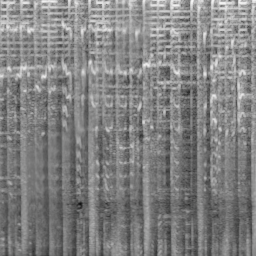
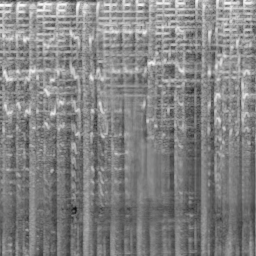
I built a diffusion model that learns from the spectrogram of a single piece of music and generates new audio material in its sonic vocabulary. Training on one source at a time keeps the compute requirement low enough for common consumer GPUs while preserving a distinct musical character.
- Diffusion
- PyTorch
- Spectrograms
View project deckOne-pound vertical spinner
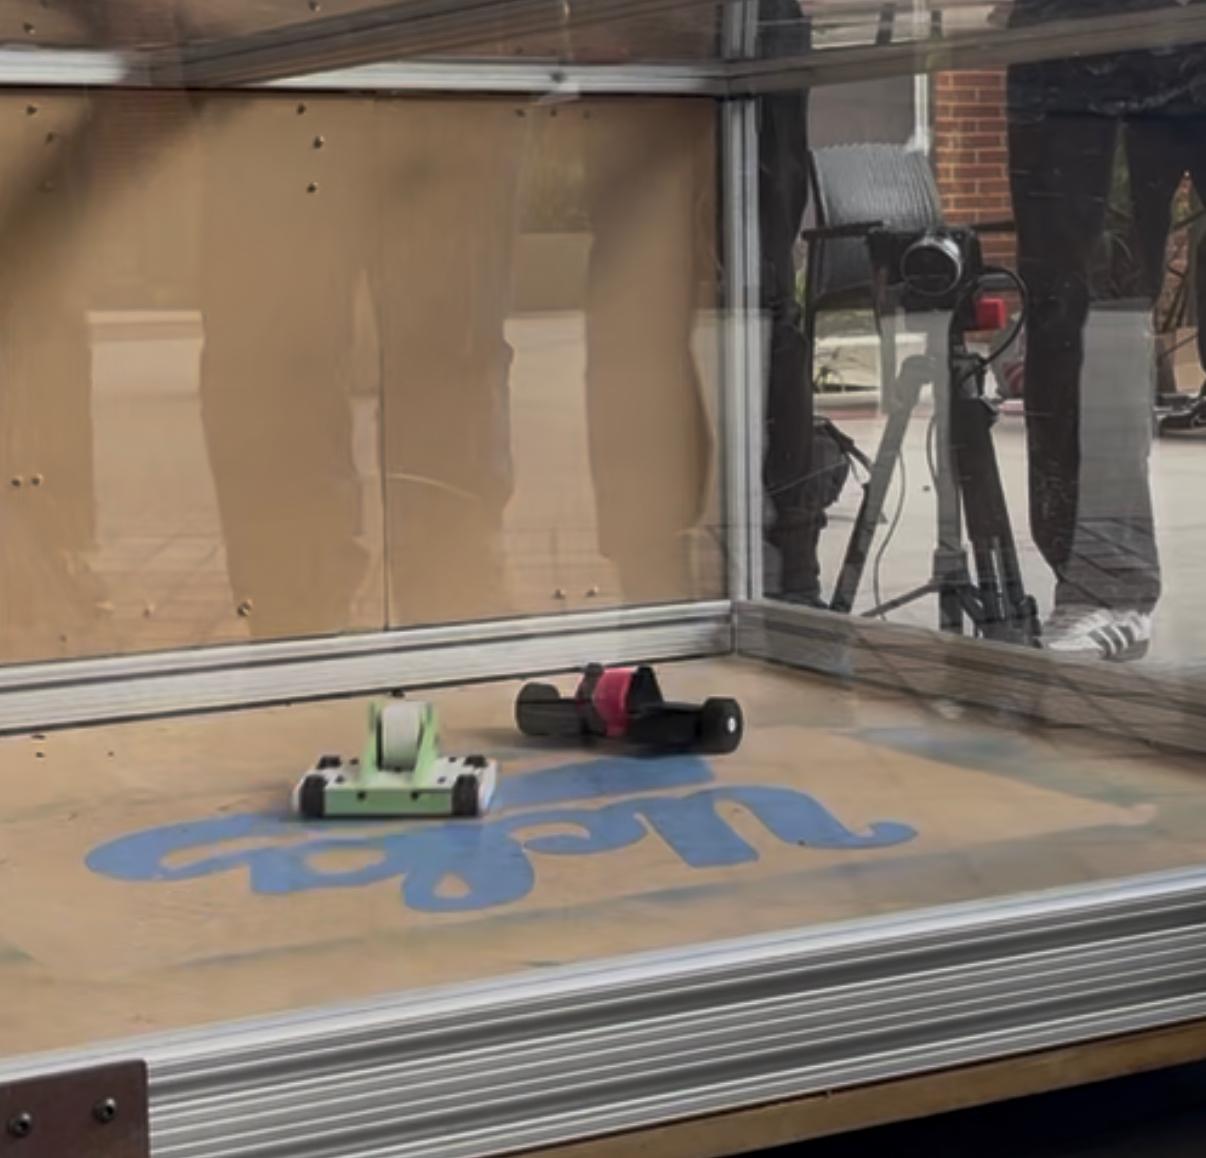
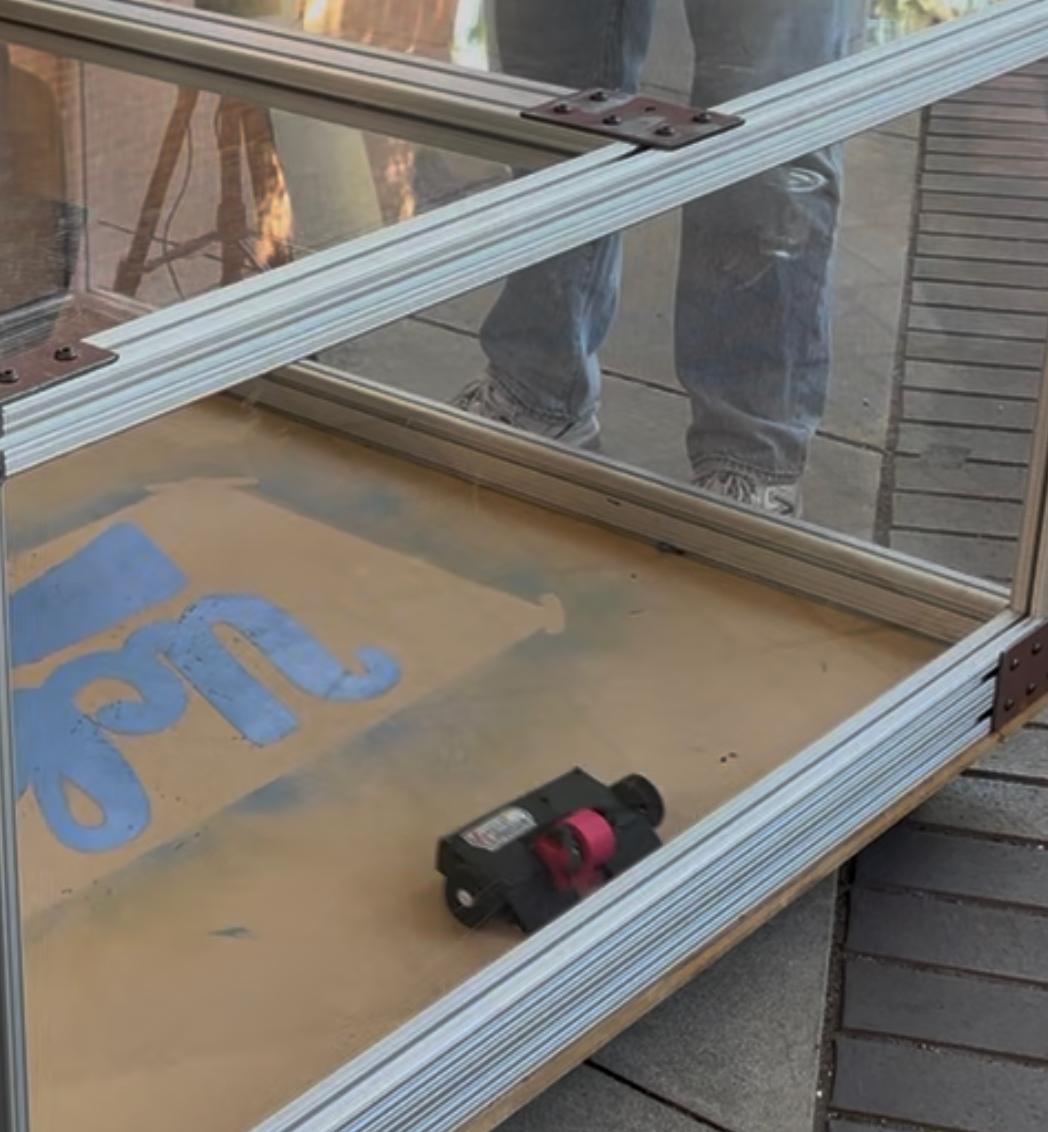
Our team designed, built, and competed with a one-pound combat robot centered on a vertical spinner. Repeated design and testing cycles balanced weapon energy, impact resistance, controllability, and reliability within a strict weight budget.
- CAD
- Rapid prototyping
- Testing
Experience Synesthesia
An art-and-engineering installation that blends sound, light, and touch. Audience members use sound-mixing podiums to reshape music in real time while the system generates evolving projected artwork across an immersive, multi-station environment.
- Interaction design
- Projection
- Audio
View concept deck